Key Highlights
- Robotics companies are advancing toward more capable models across the industry
- Charania is concentrating on a physical limitation that cannot be resolved through software improvements alone
- The challenge highlights a fundamental hardware constraint in current robotics development
Robotics Development Confronts Hardware Barriers
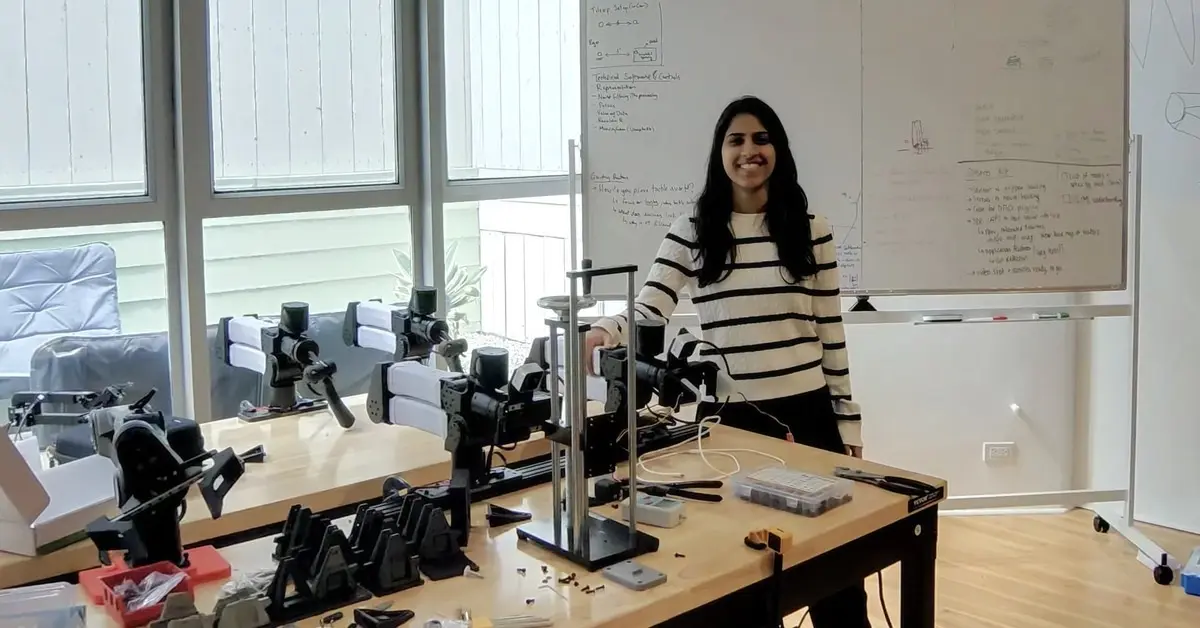
As robotics companies across the sector accelerate efforts to deploy more capable autonomous systems, industry participant Charania has directed attention toward a persistent physical limitation that software innovation alone cannot overcome. The focus underscores a growing recognition within the field that algorithmic advances, while significant, are encountering hard boundaries imposed by current hardware architectures and material constraints.
The Software-Hardware Gap in Autonomous Systems
The robotics industry has witnessed rapid progress in machine learning models, sensor fusion algorithms, and decision-making frameworks that enable increasingly sophisticated behaviors. However, Charania’s emphasis on a physical limitation points to a structural bottleneck: the mechanical, thermal, and energetic constraints of robotic platforms themselves. These include actuator precision, power density, heat dissipation, and structural compliance—factors that no amount of code optimization can fully transcend.
Why This Matters
The pursuit of more capable robotics models has largely been framed as a software challenge, with venture capital and research attention flowing toward foundation models, simulation environments, and fleet learning. Charania’s focus redirects scrutiny toward the physical layer—motors, batteries, materials, and thermal systems—that ultimately defines what any software stack can achieve in the real world. This perspective aligns with a broader industry inflection point where hardware differentiation may determine which platforms can reliably deploy advanced intelligence at scale. The next phase of robotics progress may depend less on model architecture and more on breakthroughs in actuation, energy storage, and thermal management.
Frequently Asked Questions
- What physical limitation is Charania focused on?
- The source identifies a physical limitation that software alone cannot solve but does not specify the exact constraint. Common candidates in robotics include actuator torque density, battery energy density, thermal dissipation limits, or structural compliance.
- Why can’t software solve this limitation?
- Software operates within the physical boundaries of the hardware it controls. No algorithm can generate more torque than a motor permits, store more energy than a battery holds, or dissipate heat faster than a thermal system allows.
- How does this affect robotics development timelines?
- Hardware development cycles are typically longer and more capital-intensive than software iterations. A fundamental physical bottleneck implies that roadmap progress may be gated by materials science, manufacturing advances, or component supply chains rather than code releases.